Autonomous drones · Knight Hacks IX
ARCHER
Drones that take a mission in plain English, fly it around obstacles, and report back to a live ground station.
What it is
ARCHER — Autonomous Robotic Coordination for Hazard Evasion & Reconnaissance — coordinates drones for reconnaissance and surveillance, so responders can locate missing people and watch an emergency before rescue teams reach the scene. An LLM turns a mission goal into flight commands, a deterministic autonomy layer handles geofencing, flight patterns and obstacle avoidance, and the flight controller does the real-time stabilization. Built at Knight Hacks IX with Hayden Jose, Khizar Aamir and Syed Iqbal.
What it does
- ▸Three layers, kept apart on purpose: an LLM mission brain that is never in the real-time loop, a fast deterministic autonomy layer, and PX4 firmware for hard real-time flight control over MAVLink.
- ▸Mission brain on the Anthropic API: a plain-English goal like "take off, survey the field, then come home" becomes a sequence of commands, reading each result back to choose the next one.
- ▸An MCP server exposes nine flight tools — status, take off, go to, orbit, survey, patrol, hold, return home, land — so a live Claude Code session can fly the drone directly.
- ▸Potential-field obstacle avoidance that plans a path around known obstacles before flying it, plus patrol, orbit and lawnmower survey patterns inside a bounded geofence.
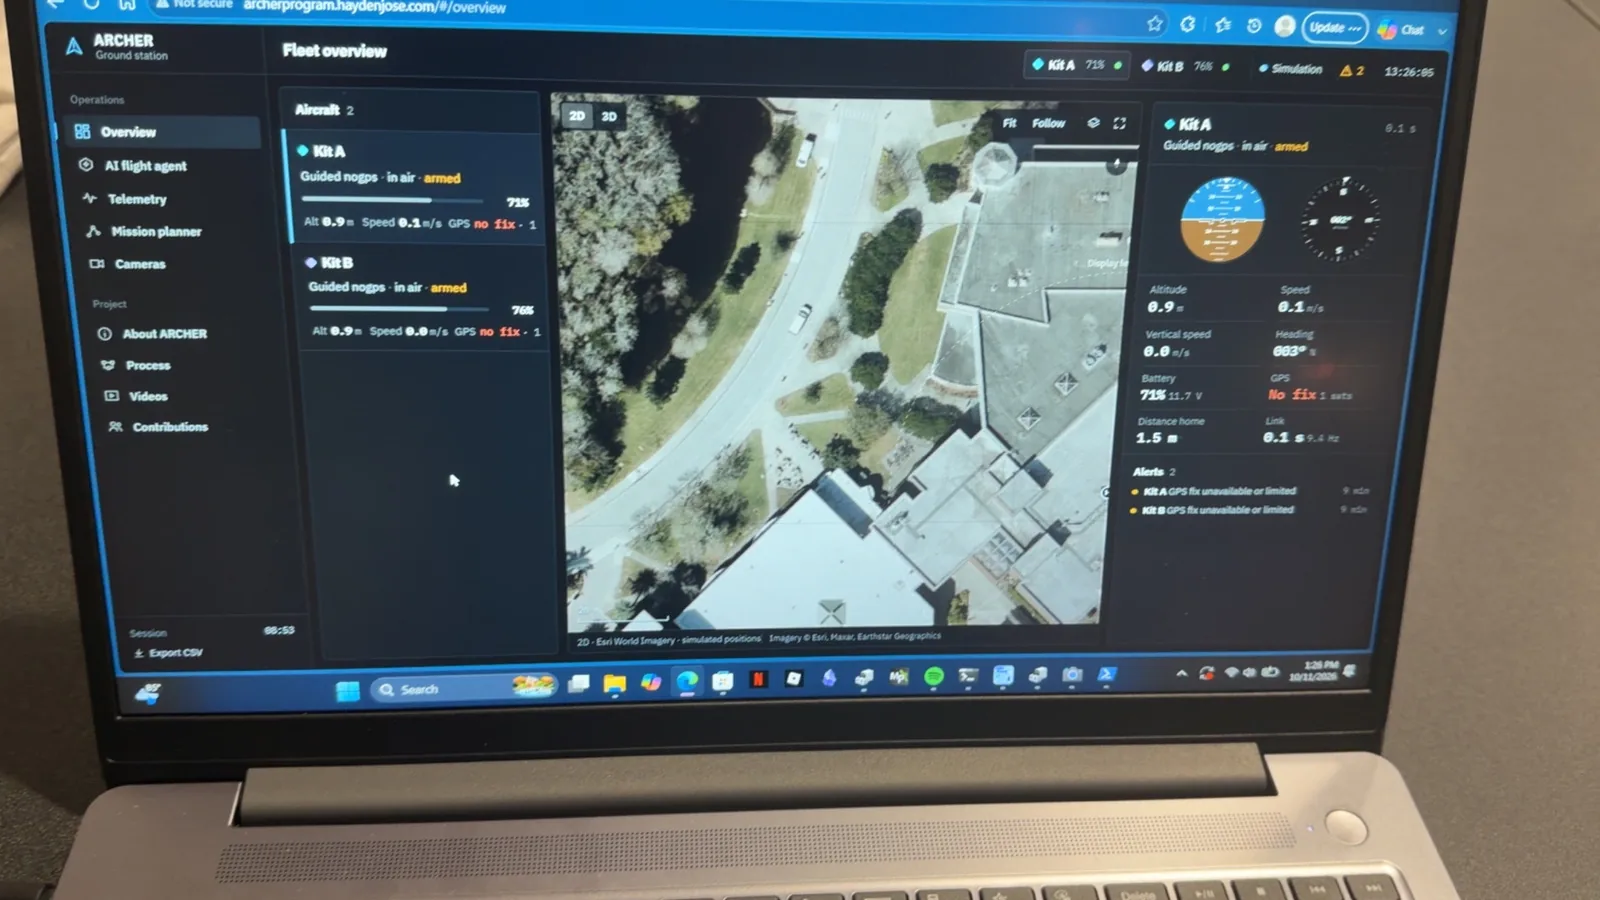
- ▸Ground-control web app with live telemetry, a 2D and 3D map, and camera feeds run through YOLO detection with a monocular distance estimate for each object.
- ▸Multi-drone safety-bubble avoidance proven in simulation: three drones cross the same point and repel each other apart.
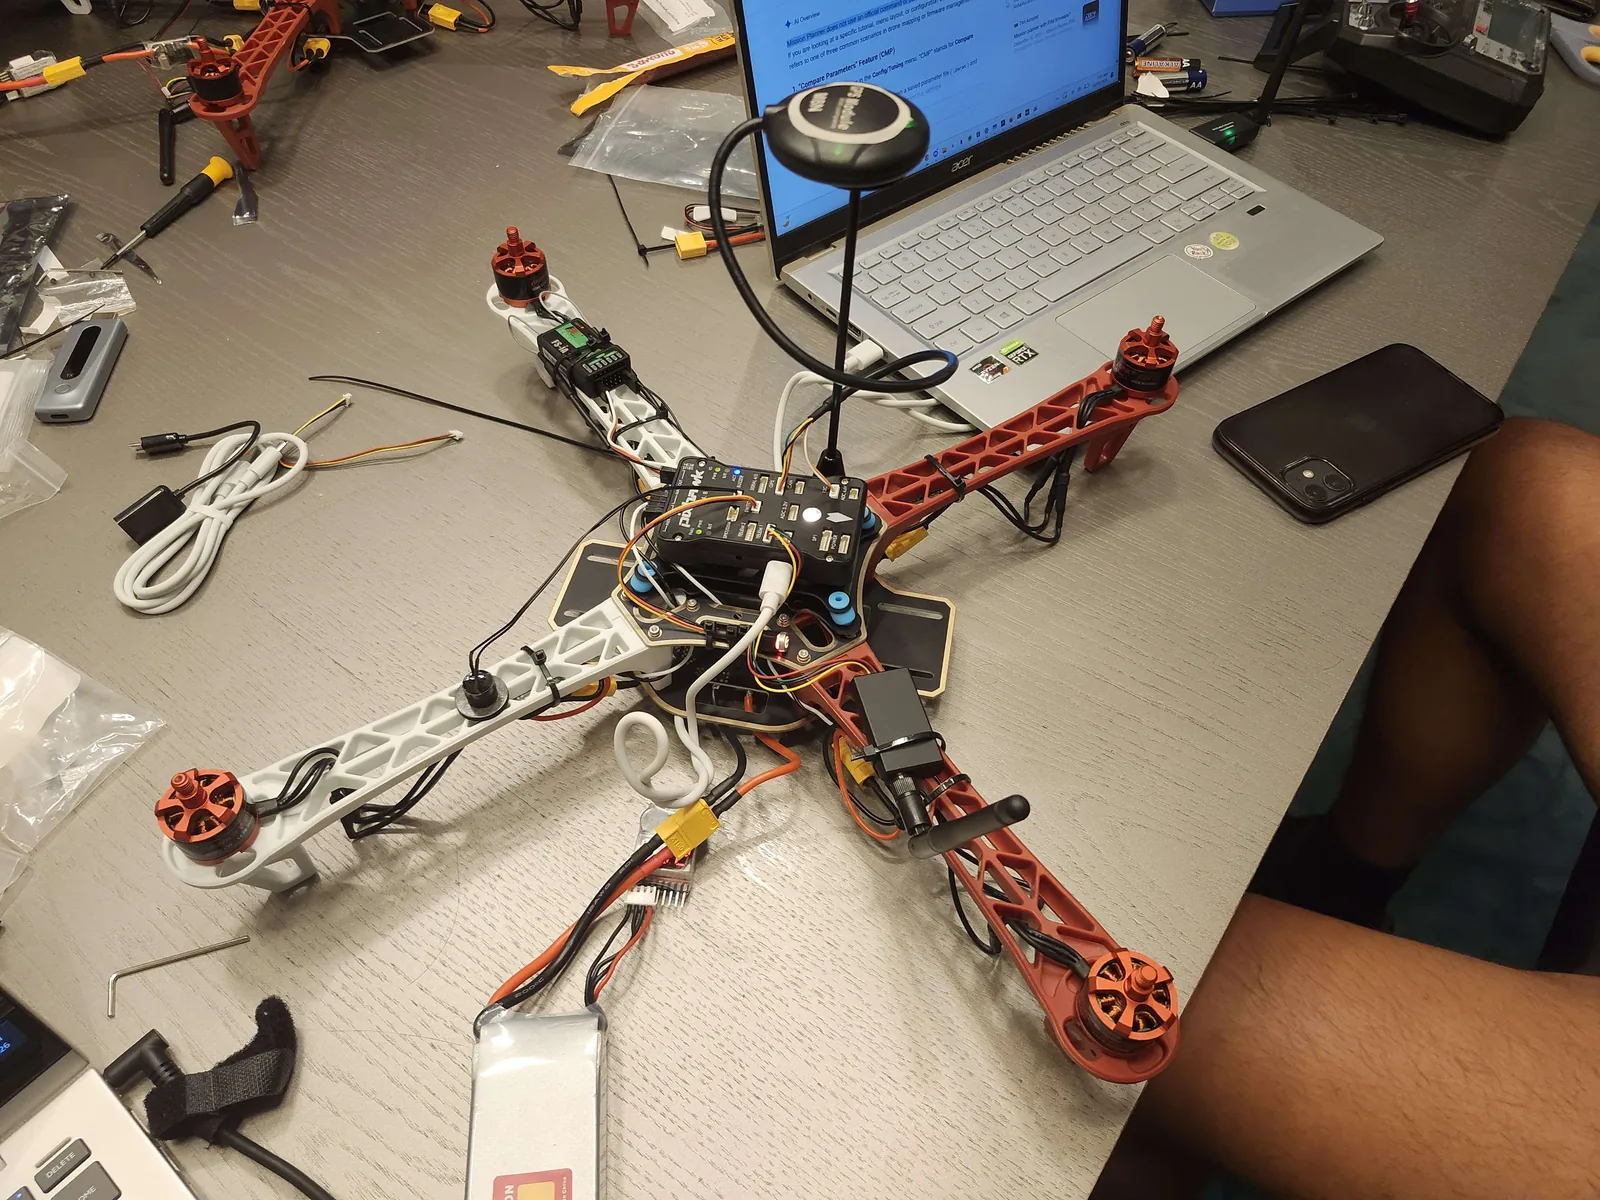
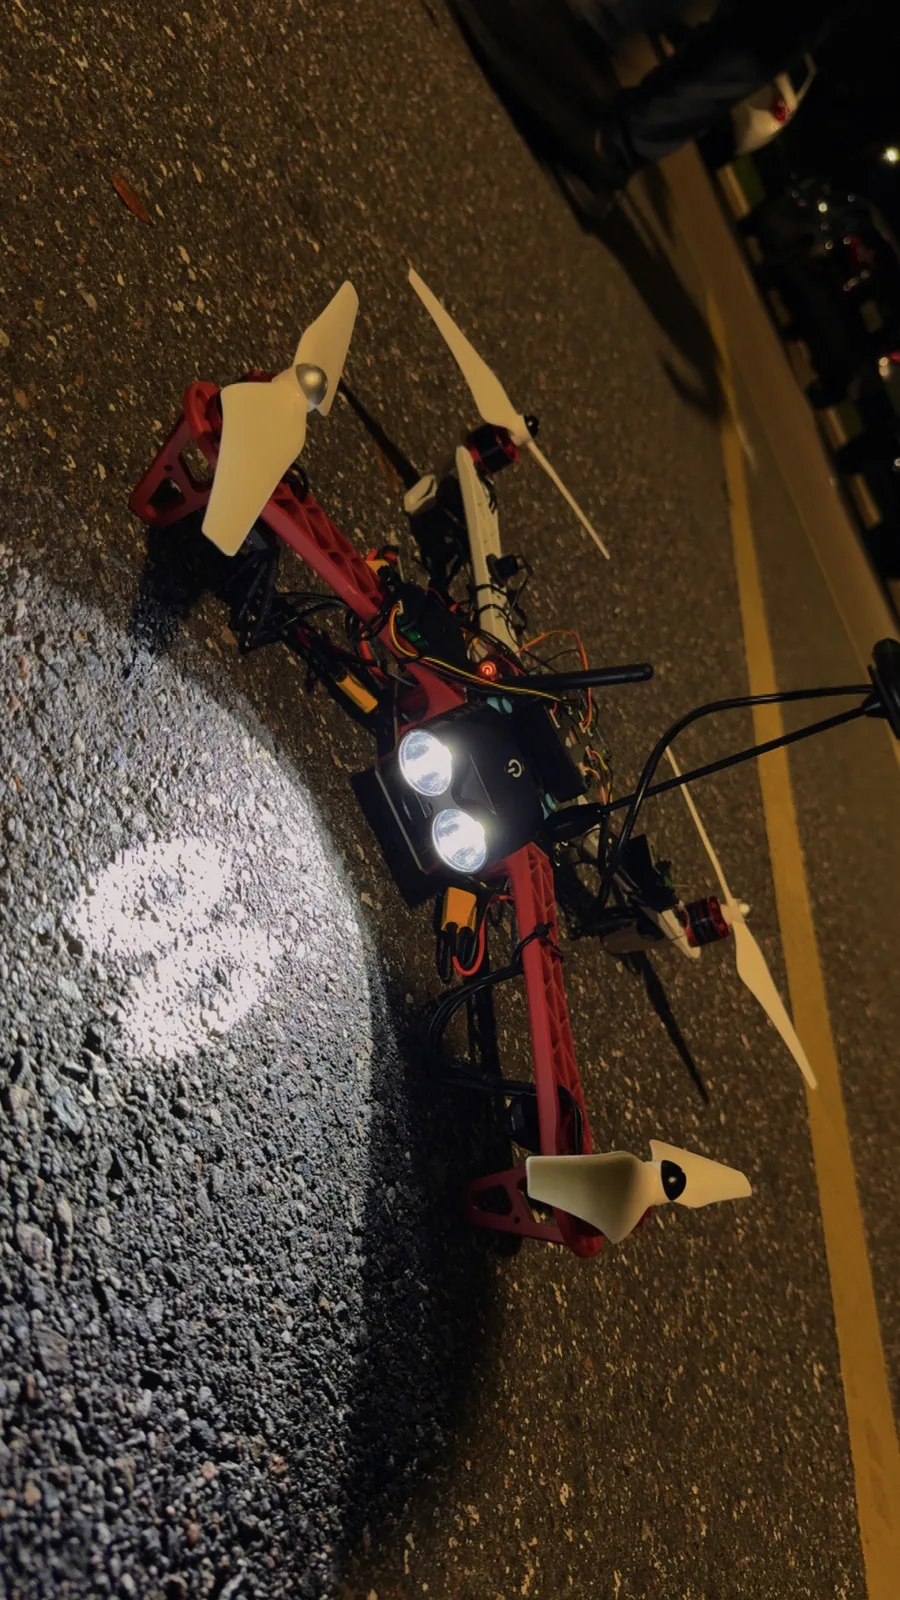
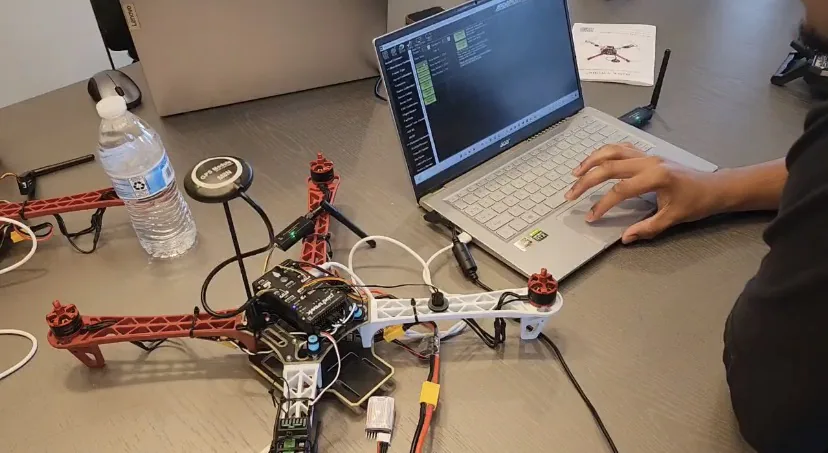
- ▸Developed against PX4 SITL and Gazebo first, then real F450 builds on Pixhawk 2.4.8 running ArduCopter, flown from a laptop over a SiK telemetry radio with no RC transmitter.
Stack
- Python
- PX4 SITL + Gazebo
- ArduPilot
- MAVSDK / MAVLink
- Anthropic Claude API
- MCP
- YOLOv8 + OpenCV
- CesiumJS
- WebSockets
- Pixhawk
Pictures
Video
Live demo
Live demo coming soon